Mechanical engineering · Robotics · Medical devices

William Harris

I build robots that help in emergencies.

I'm a mechanical engineering master's student at UC San Diego. I design the hardware: frames and mechanisms, motors and their control, and the tests that show whether a design does what the model says. Right now that means rescue robots in the Advanced Robotics and Controls Lab.

Focus
Rescue robotics · haptics · medical devices
Program
M.S. Mechanical Engineering '27 · B.S. '25, minor in Design
School
UC San Diego
Lab
ARCLab · advisor Prof. Michael Yip
Status
Available for full-time roles and internships, summer 2027

See my projects Resume Email me
William Harris sitting by a fountain
La Jolla, CA

About

About me

I'm William Harris, a mechanical engineer and master's student at UC San Diego. I like the part of robotics where an idea has to survive contact with a real machine: frames, mechanisms, motors, and the tests that show whether the model was right.

Most of my time goes to rescue robots. At the Advanced Robotics and Controls Lab, with my thesis advisor Prof. Michael Yip, I built the frame and center-of-mass stage for a mobile manipulator for human-extraction research, a leg that changes shape between fast travel and heavy dragging (ICRA 2026), and the optimization and hexapod design that follow from it.

Before that I spent three years at Triton Robotics, from machining chassis parts to leading the Hero robot's redesign to serving as president of the 80-member team. I'm looking for full-time roles and internships in medical robotics and medical devices, where careful mechanical design and testing decide whether something is safe to use around people.

News

  • Sep 2026Finished the first stage of optimizing the leg geometry for the hexapod, and started planning the reinforcement learning stage.
  • Jun 2026Presented our morphing-leg paper at ICRA 2026.
  • Nov 2025Posted the morphing-leg paper to arXiv.

Click an entry for details

  1. Expected Jun 2027M.S. Mechanical EngineeringUC San Diego

    GPA 3.68. Coursework in robotics, linear control, haptics, soft robotics, and parametric identification.

  2. Jun 2024 – PresentGraduate ResearcherARCLab · advisor Prof. Michael Yip

    A shape-changing 5-bar leg (+83% foot force, ICRA 2026), the frame and center-of-mass stage for a mobile manipulator, and the optimization behind a hexapod rescue robot.

  3. Jul 2023 – Jun 2024PresidentTriton Robotics

    Led an 80-member team and rebuilt the training program, which brought in about 40 new members in a year.

  4. Dec 2022 – Jun 2023Team Lead, Baja Del SolUCSD Global TIES

    Revived a solar water heater project for an orphanage in Tijuana, and translated between the students and the house parents.

  5. May 2022 – Jul 2023Hero Robot LeadTriton Robotics

    Led the Hero redesign, with an X-drive and a slip-ring turret: +40% rotation speed and +50% targeting accuracy.

  6. Sep 2021 – May 2022Mechanical Team MemberTriton Robotics

    Designed and built a lighter Hero chassis with 30% less aluminum tubing and a modular suspension.

  7. Sep 2021 – Jun 2025B.S. Mechanical EngineeringMinor in Design · UC San Diego

    Senior capstone: a hexapod rescue-robot leg, sponsored by ARCLab.

Projects

Things I've built

ARCLab · Research · ICRA 2026

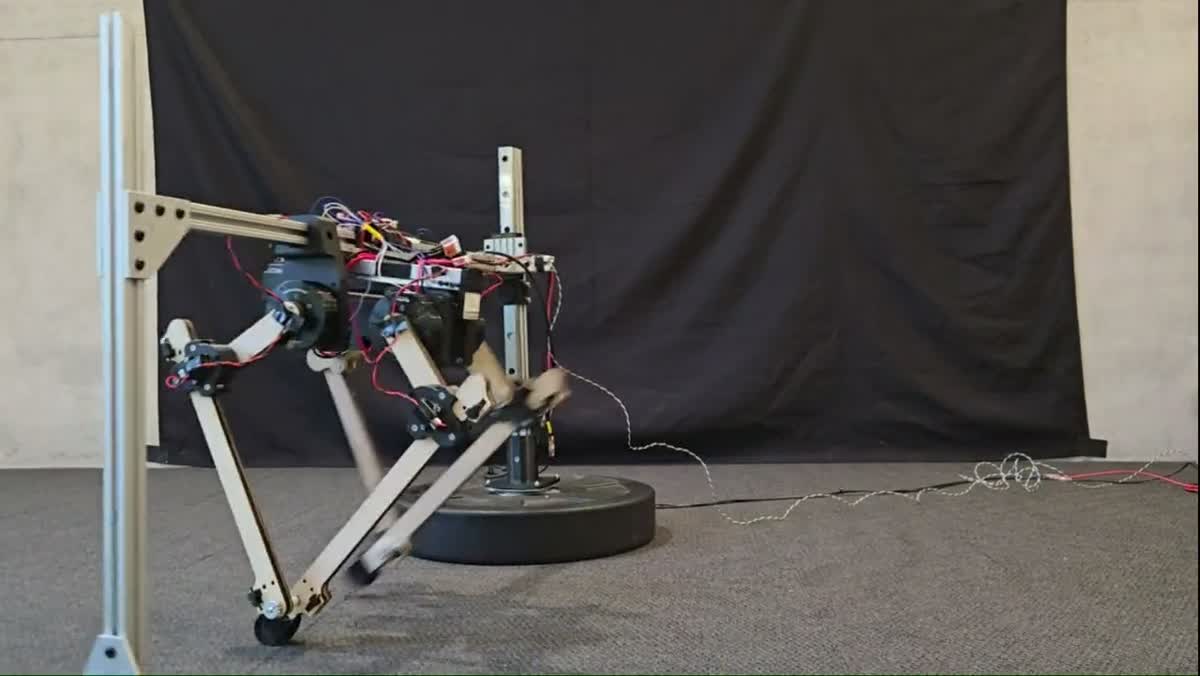
Adaptive Morphing Leg for Search and Rescue

Changing link lengths raised measured foot force from 58 N to 106 N on the same motors, and the biped used it to drag a 2.3 kg load.

My part Designed and built the testbed and capstan actuator, wrote the control. Co-first author.

  • SolidWorks
  • Ansys FEA
  • Python
  • CAN
  • CubeMars AK60-6

Hexapod Rescue Robot and Leg Optimization

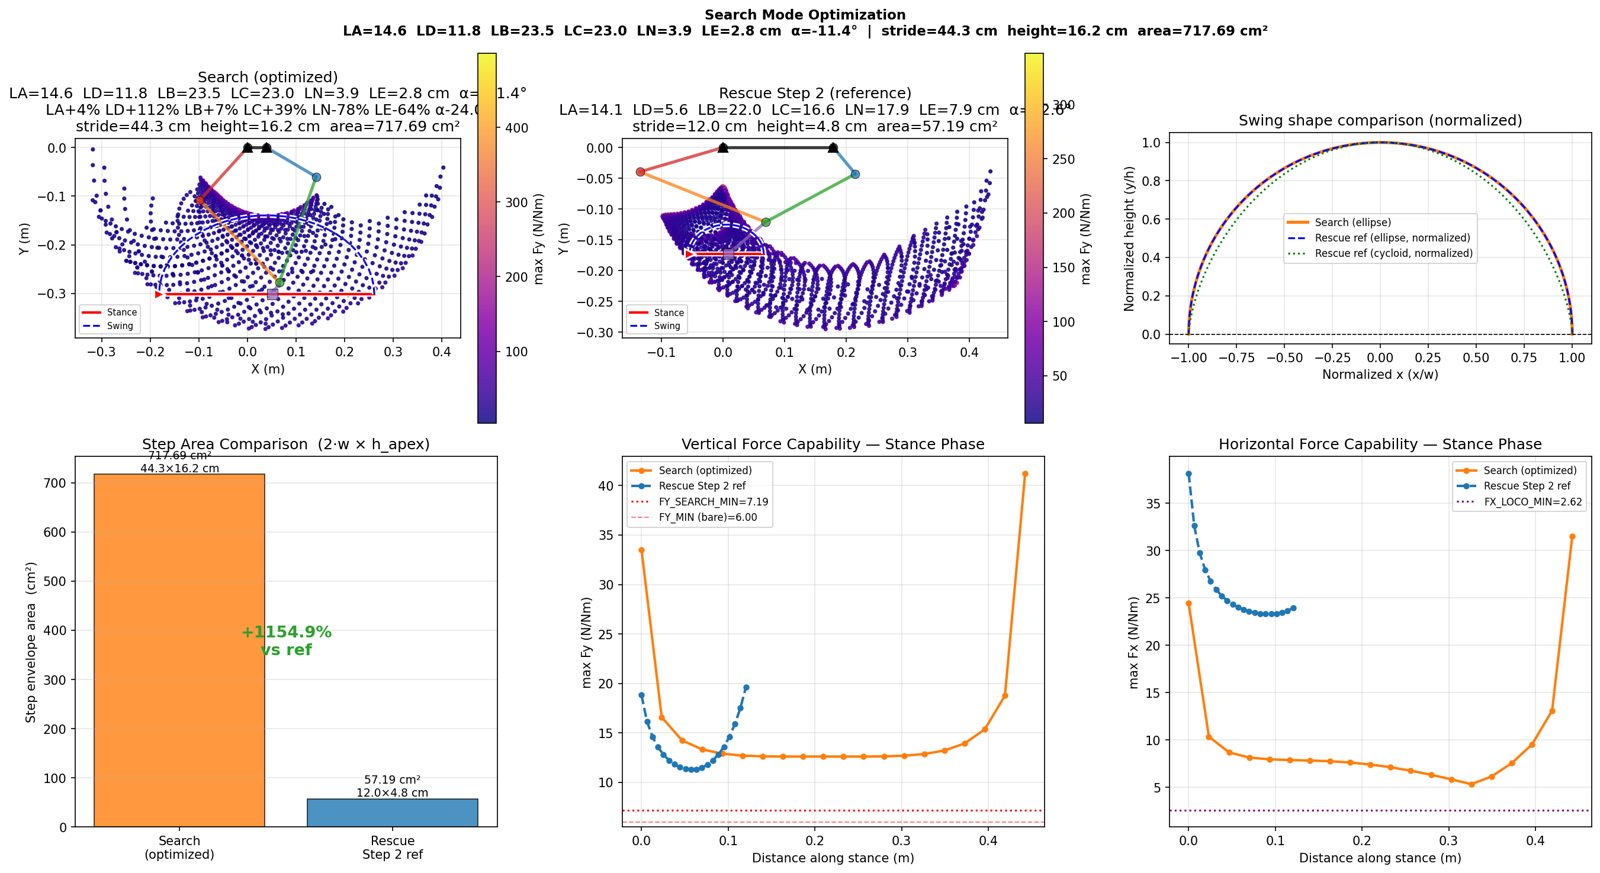
Optimizing the leg geometry and footpath, and designing the 11 kg hexapod it runs on.

My part Wrote the kinematic model and optimizer, and designed the hexapod.

  • Python
  • MATLAB
  • SolidWorks

ARCLab, UC San Diego · 2025 – Present

Mobile Manipulator for Rescue Operations

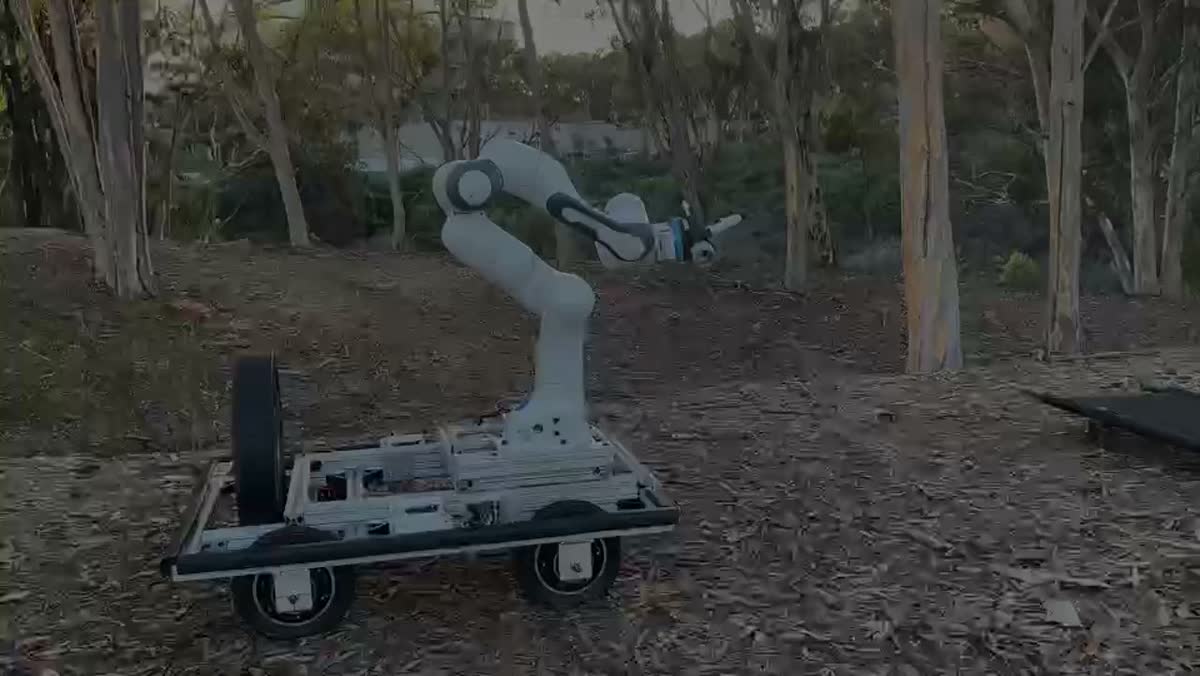
A mobile base with two Franka arms and a moving counterweight for safe human extraction research.

My part Built the frame, the center-of-mass stage, and the soft gripper.

  • SolidWorks
  • Ansys FEA
  • ODrive

ARCLab, UC San Diego · Jun 2024 – Present

Leadership & coursework

Triton Robotics Competition Robot

Two generations of a competition robot chassis, then a year leading the 80-member team.

My part Hero robot lead, then team president.

  • SolidWorks
  • CNC machining
  • manual machining

Triton Robotics, UC San Diego · Sep 2021 – Jun 2024

Particle-Jamming Limb Stabilization

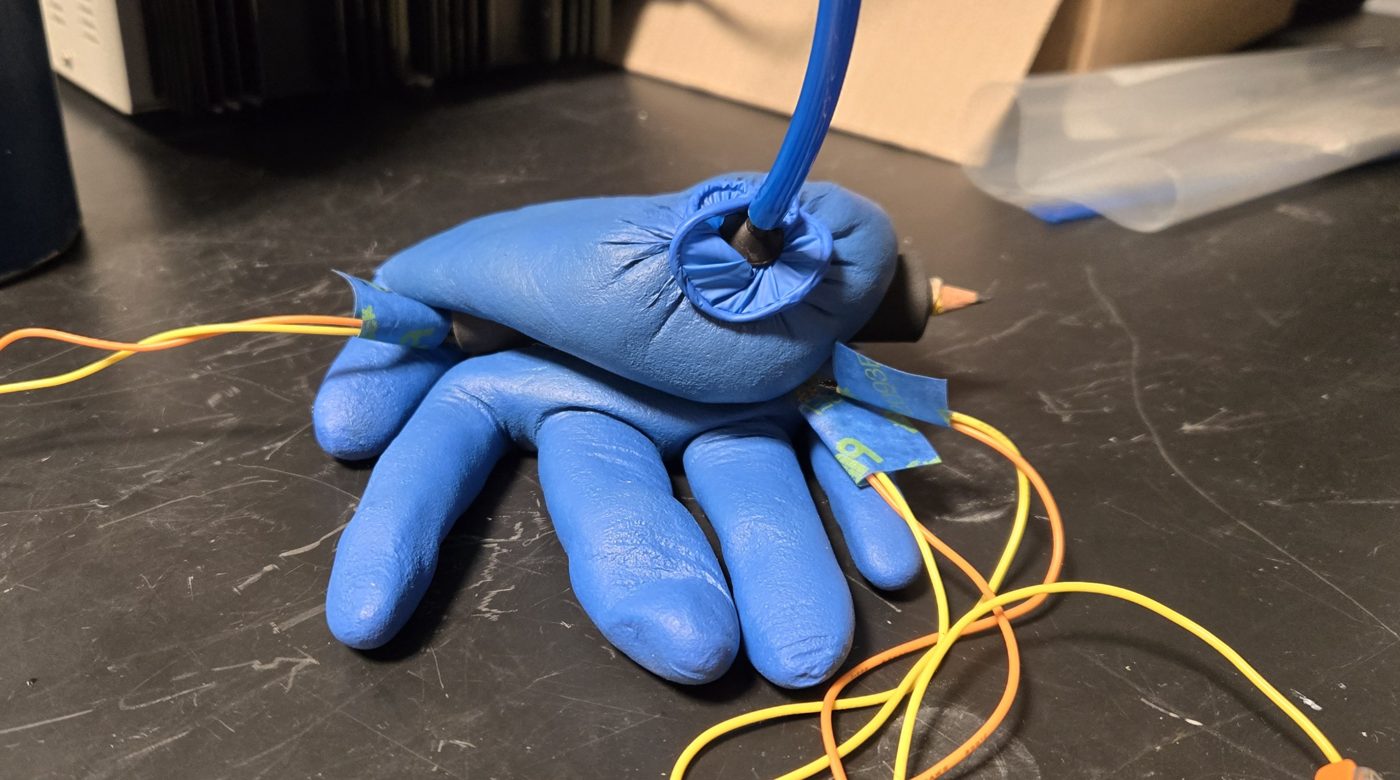
A vacuum-stiffening glove splint that out-held strap splints 1.6 to 4 times in pull-out tests.

My part Solo: design, build, and test.

  • Vacuum pneumatics
  • FSR arrays
  • Arduino

Soft Robotics course, UC San Diego · Oct – Dec 2025

PHABS Haptic Teleoperation Device

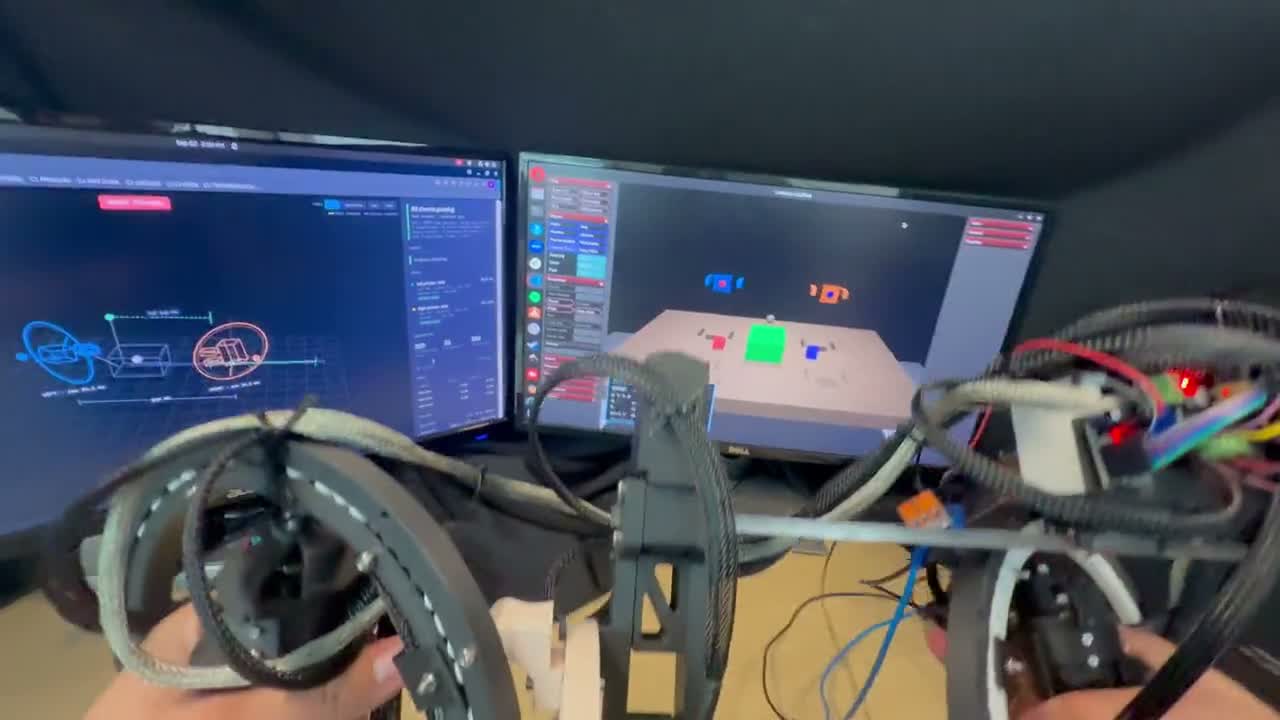
A handheld bimanual haptic device that lets operators feel contact while teaching robots.

My part Built the first lateral force-feedback prototype.

  • Arduino Mega
  • PyBullet
  • Vive trackers

MAE 219 Haptic Systems, UC San Diego · 2026

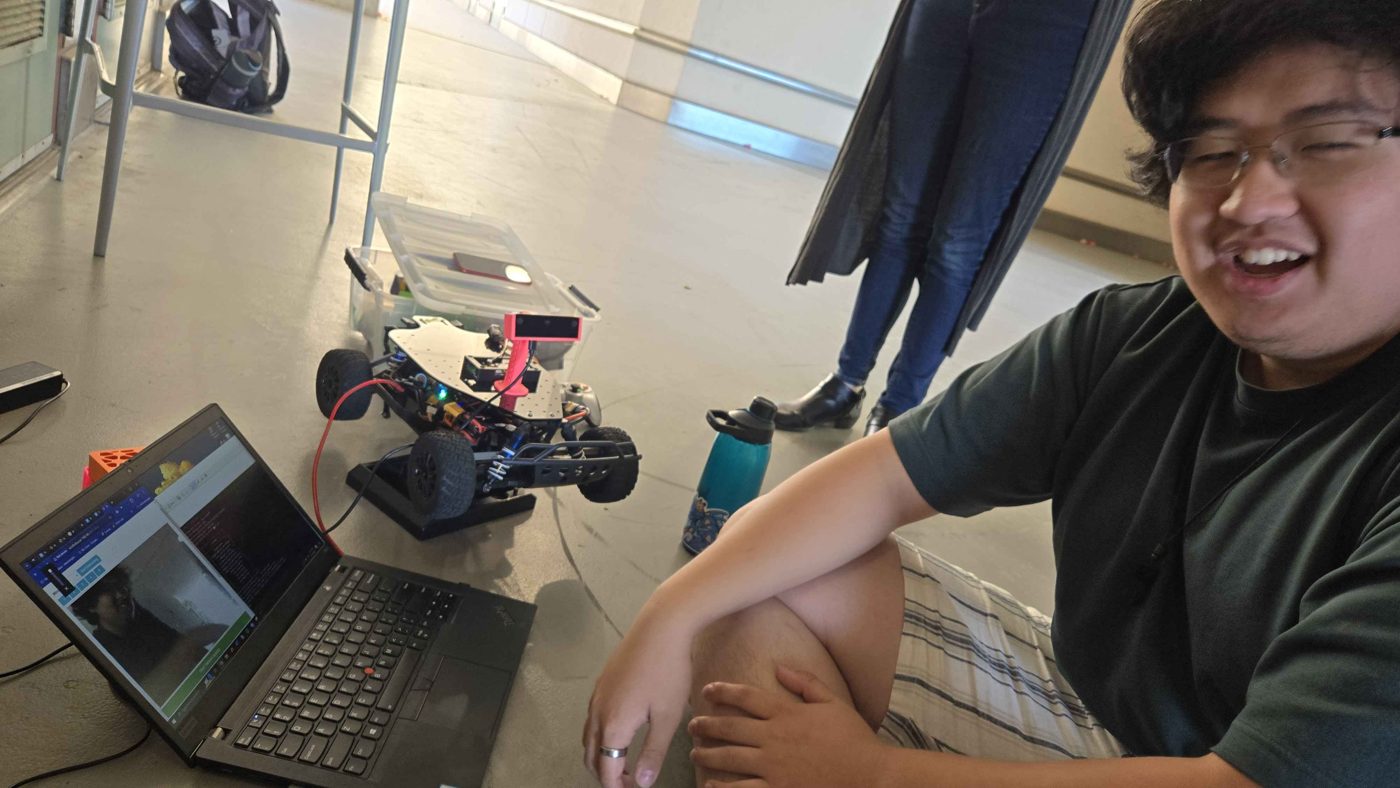
Line-Following Car That Plays Music

A ROS 2 car that follows a line and plays a note when it sees a colored marker.

My part Hardware setup and system integration.

  • ROS 2
  • Ubuntu 20.04
  • Docker

MAE 148 Introduction to Autonomous Vehicles, UC San Diego · Summer 2024

Mobile Manipulation Capstone

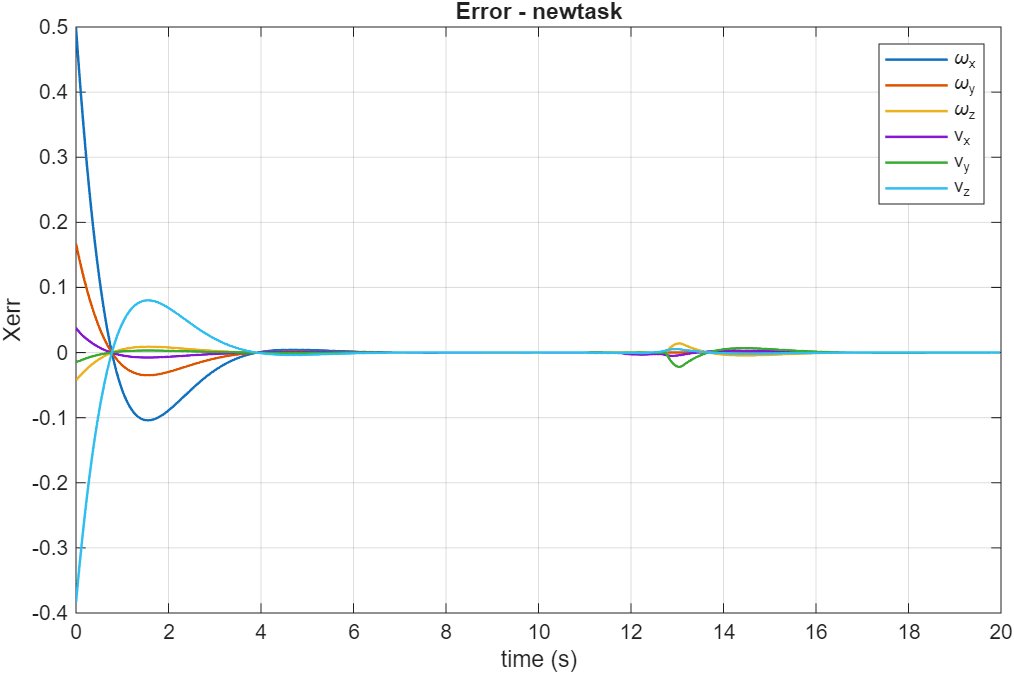
A simulated mobile manipulator with a feedforward plus PI controller, run in CoppeliaSim.

MAE 204 Robotics · 2026

Rectilinear System Identification

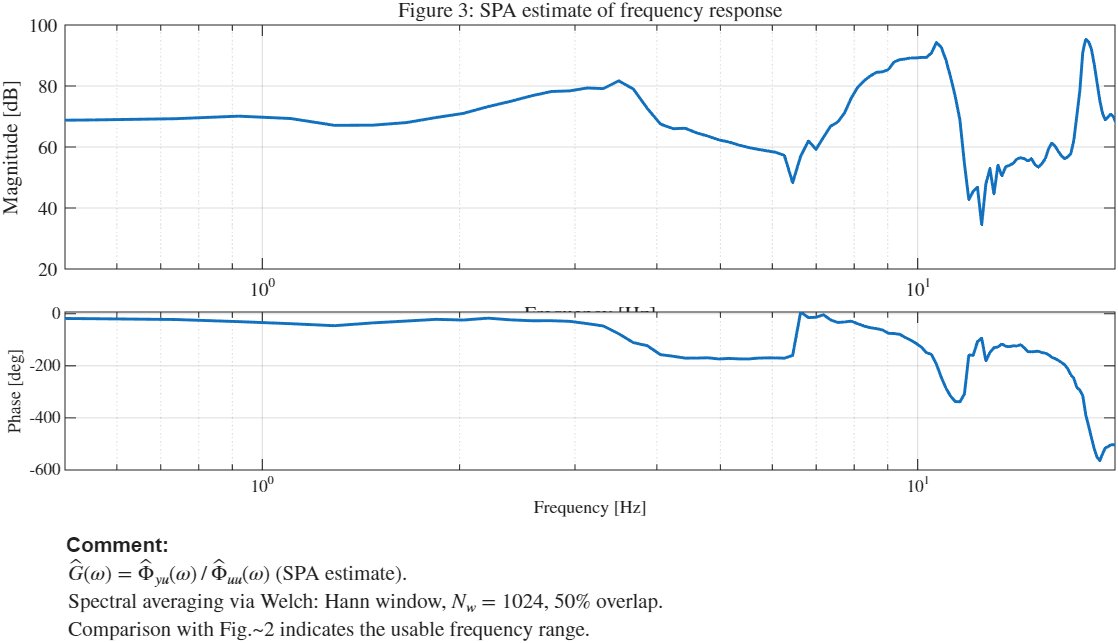
FIR and state-space models of a three-cart spring-mass system, from experimental data.

MAE 283A Parametric Identification · 2026

Automated Shaft Design

A MATLAB script that sizes shafts under bending and torsion, checked against AI-generated code.

My part Individual project.

MAE 190 Design of Machine Elements · Fall 2024

Publications

Papers

  1. Dynamically Extensible and Retractable Robotic Leg Linkages for Multi-task Execution in Search and Rescue Scenarios

    W. Harris, L. Yager, S. Sylvester, E. Peiros, M. C. Yip

    ICRA 2026 · Accepted · Co-first author

  2. Discovery to Extraction: Biomechanically Safe Manipulation of Human Limbs Using Robotic Manipulation in Search and Rescue Scenarios

    Science Robotics · In review · Contributor

Tools

Toolbox

Design and fabrication
  • SolidWorks
  • Creo
  • Ansys FEA
  • Fusion 360 CAM
  • DFMA
  • CNC and manual machining
  • Laser and waterjet
  • 3D printing
  • MIG welding
Electronics and controls
  • BLDC motor control
  • CAN
  • PCB design (EasyEDA)
  • Circuit design
Software
  • Python
  • MATLAB
  • C (Arduino)
  • ROS 2
  • Embedded Linux
  • MuJoCo
Relevant coursework
  • Robotics (MAE 204)
  • Linear Control (MAE 143B)
  • Haptic Systems (MAE 219)
  • Soft Robotics (MAE 249)
  • Parametric Identification (MAE 283A)
  • Design of Machine Elements (MAE 190)
  • Intro to Autonomous Vehicles (MAE 148)
  • Mechanical Design capstone (MAE 156A/B)

Off the clock

Outside the lab

When I'm not in the lab, you'll usually find me on a bike trail, on a badminton court, or testing a new recipe. I lift, I review movies with friends, and I follow Formula 1.

Full résumé Education, experience, projects, and skills in one page.
Open PDF ↗